Description
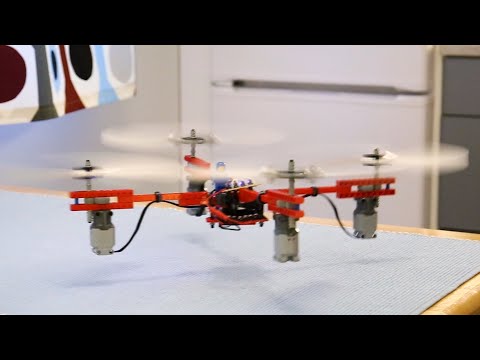
The motors, propellers and frame are made of Lego. Non-Lego parts are the battery, radio receiver and flight controller. After building I fly this quadcopter indoors and outdoors. Enjoy!
Drone specs:
Motors (4x): Lego L-motor [88003-1]
Propeller blades (8x): Lego Propeller 1 Blade 14L [89509]
Gearing: 1:1.67 gear-up for each rotor
Frame: Lego liftarms and other Lego parts (look at 11:41 component list)
Flight controller: Matek F411-mini
Motor driver circuit (4x): MOSFET IRLR2905 + Schottky diode 1N5819 + Resistor 12 kOhm (look at 03:57 circuit diagram)
Radio receiver: FrSky R-XSR Micro 2.4GHz
Radio transmitter: FrSky X-Lite 2.4GHz
Battery: LiPo 9s 33.3V 200 mAh (made out of nine Turnigy nano-tech 200mAh 3.7V 35-70C Pico)
Weight with battery: 410 grams
Max thrust: 470 grams
Flight time: about 2 minutes
Betaflight settings diff:
---------------------------------------------------
# version
# Betaflight / STM32F411 (S411) 4.1.1 Nov 15 2019 / 12:55:17 (1e5e3d369) MSP API: 1.42
# manufacturer_id: MTKS board_name: MATEKF411 custom defaults: YES
# start the command batch
batch start
board_name MATEKF411
manufacturer_id MTKS
# resources
# Note: pass telemetry to transmitter (http://www.mateksys.com/?portfolio=f411-mini#tab-id-4)
resource MOTOR 5 NONE
resource SERIAL_TX 11 B03
# feature
feature -AIRMODE
# map
map TAER1234
# serial
serial 30 32 115200 57600 0 115200
# aux
aux 0 0 0 1700 2100 0 0
aux 1 1 1 900 1700 0 0
aux 2 28 1 1300 2100 0 0
aux 3 47 1 1700 2100 0 0
# master
set min_throttle = 700
set min_command = 0
set use_unsynced_pwm = OFF
set motor_pwm_protocol = OFF
set motor_pwm_rate = 480
set align_board_yaw = 135
set pid_process_denom = 16
set gyro_1_align_yaw = 1800
profile 0
# profile 0
set p_pitch = 200
set i_pitch = 0
set d_pitch = 0
set f_pitch = 0
set p_roll = 200
set i_roll = 0
set d_roll = 0
set f_roll = 0
set p_yaw = 60
set d_min_roll = 0
set d_min_pitch = 0
rateprofile 0
# rateprofile 0
set roll_rc_rate = 50
set pitch_rc_rate = 50
# end the command batch
batch end